Shubham Nagar
  • ERH hackathon, 2nd in track. FLUX.3 Action world model placing Snickers, 2× speed

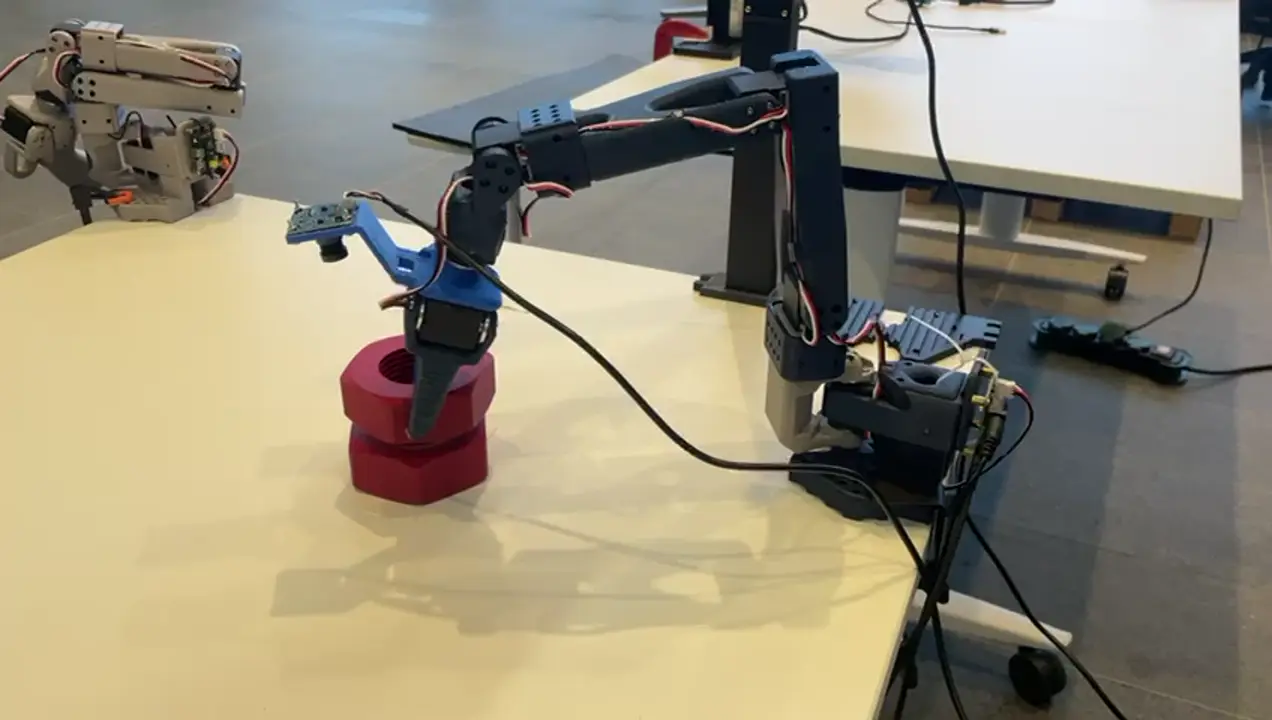
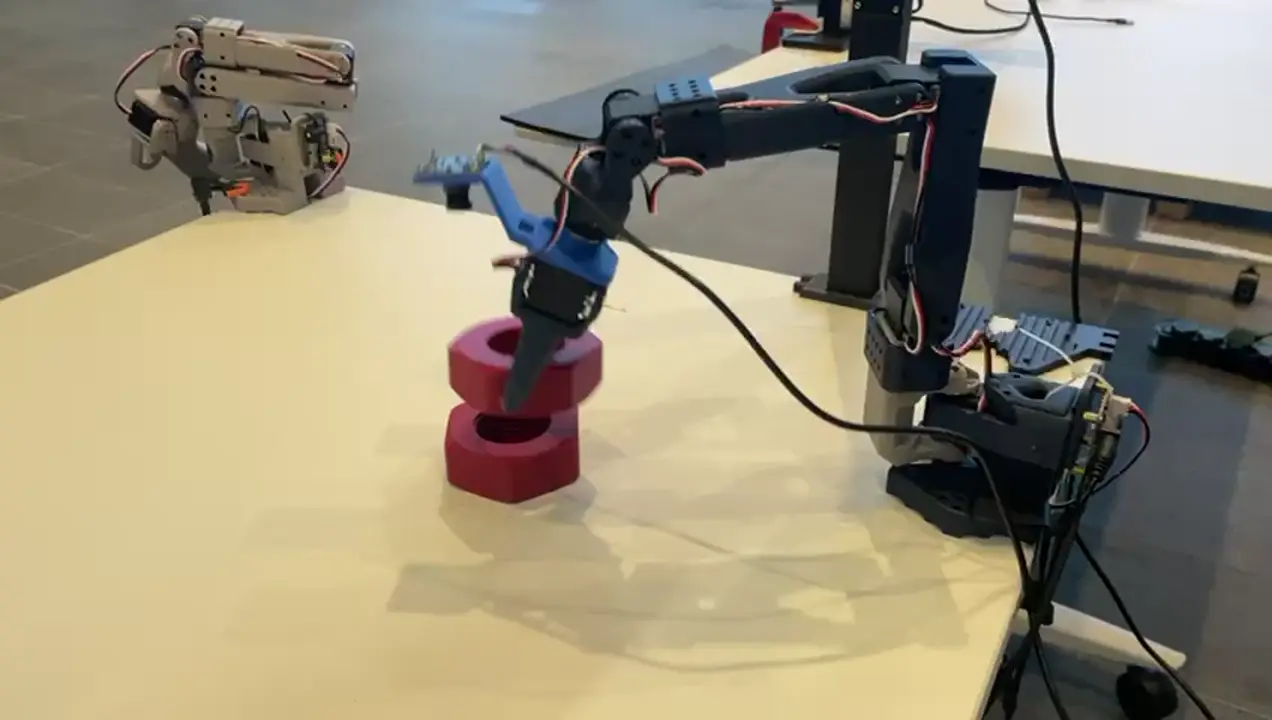
  • SmolVLA nut stacking on a physical SO-101. 75% full-stack success

  • FLUX.3 Action world model stacking paper cups, 2× speed

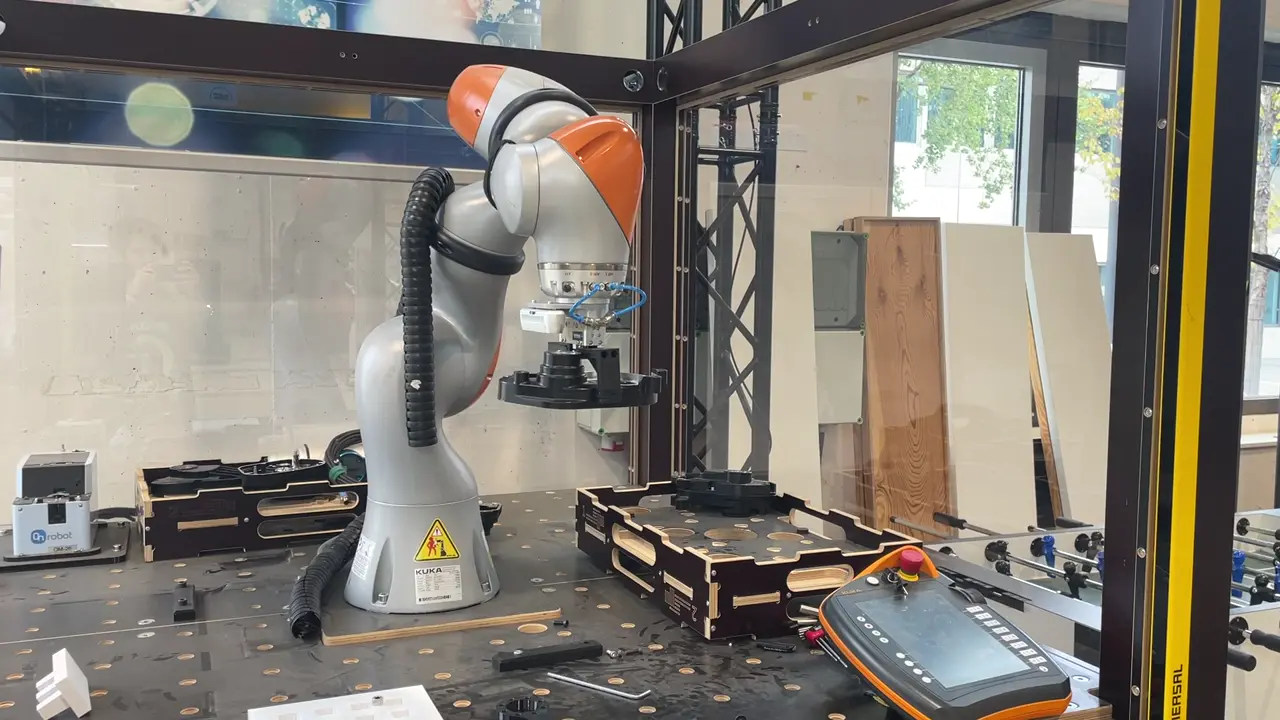
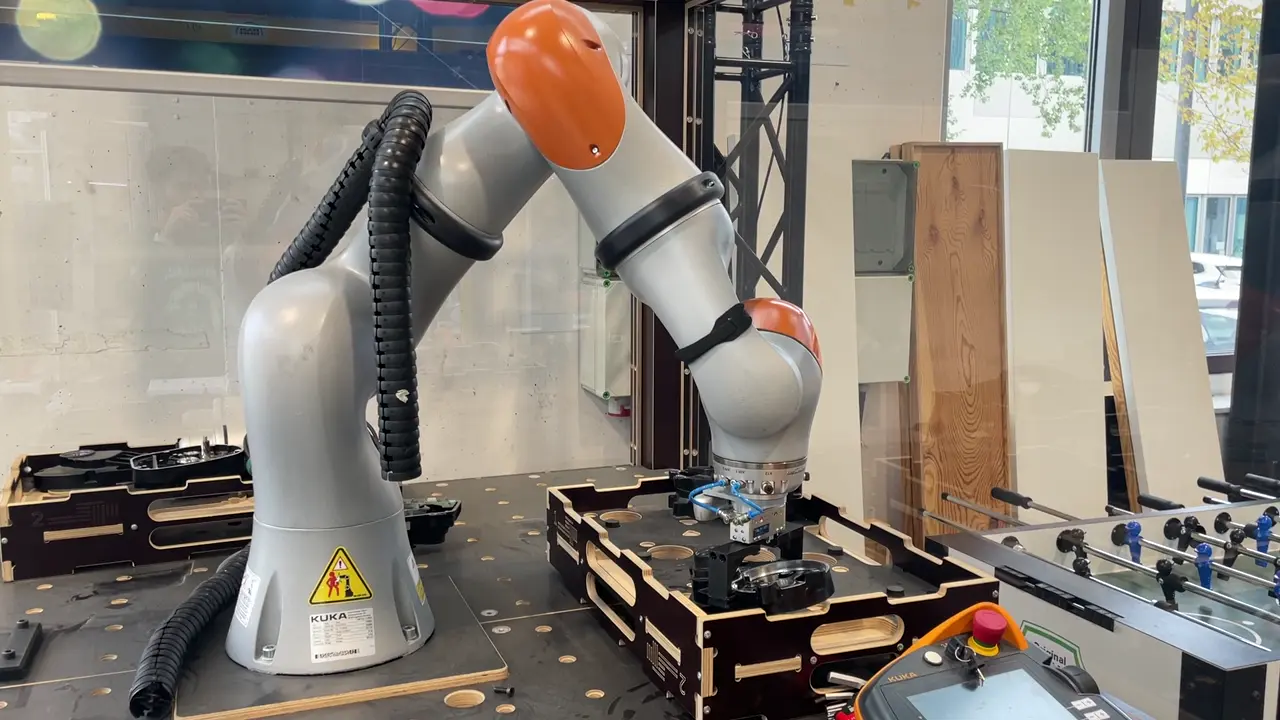
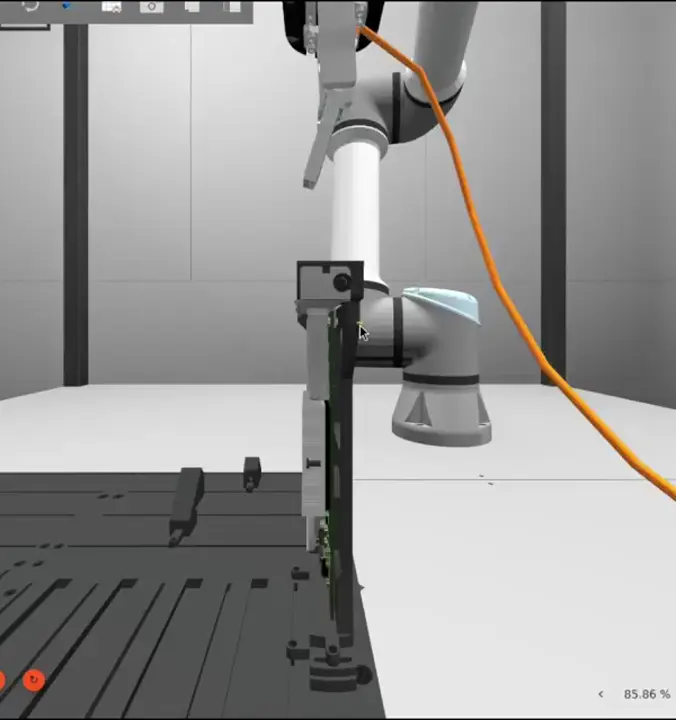
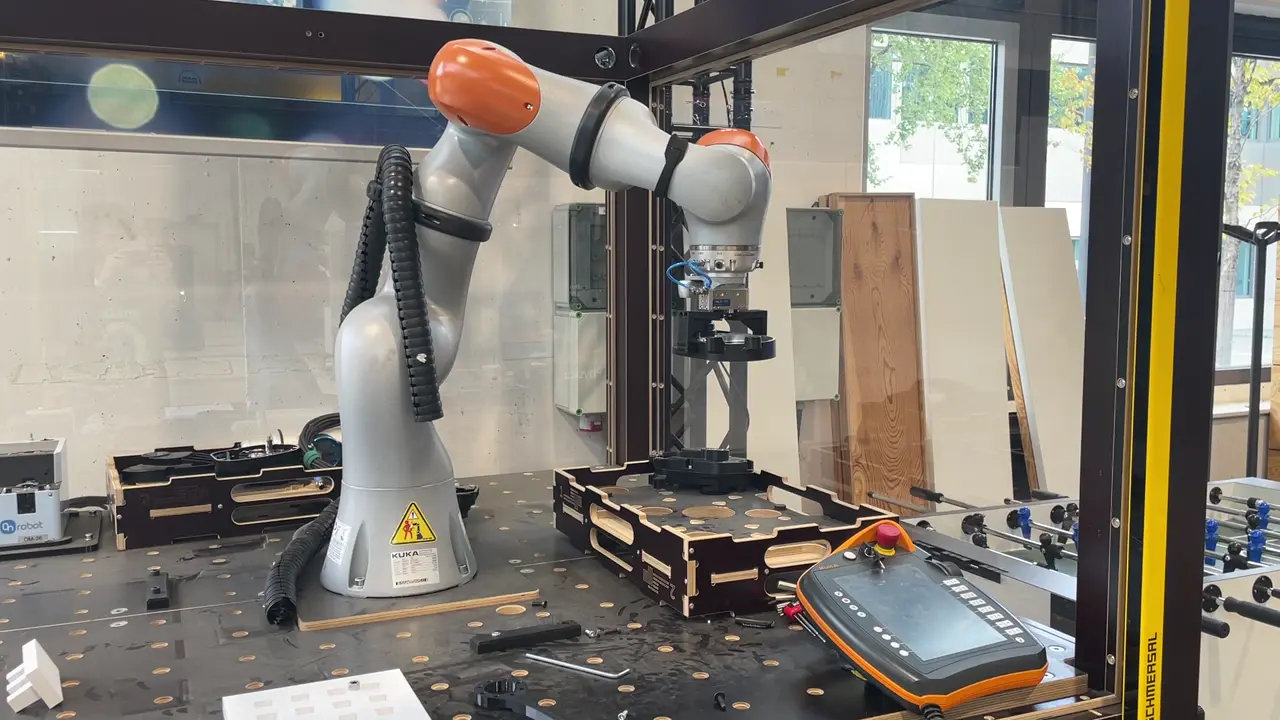
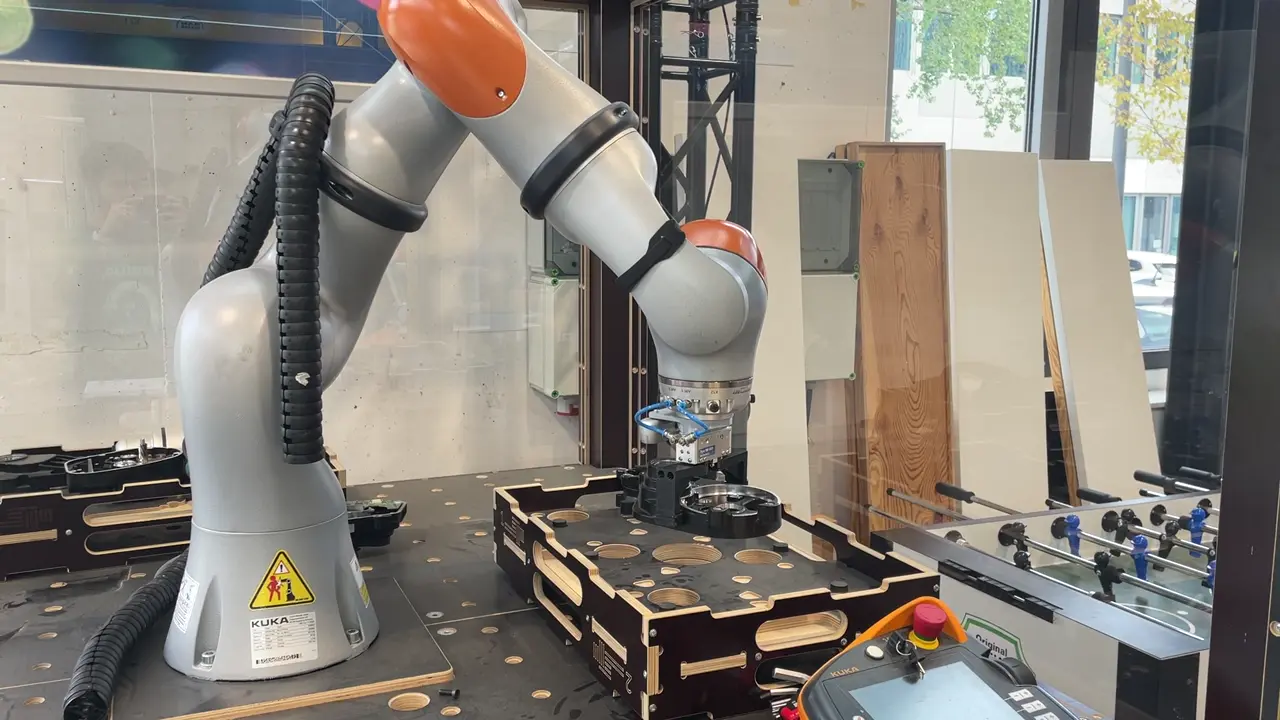
  • KUKA iiwa lowering its gripper into a disassembly fixture

    KUKA iiwa at WZL. Perception to MoveIt pick-and-place

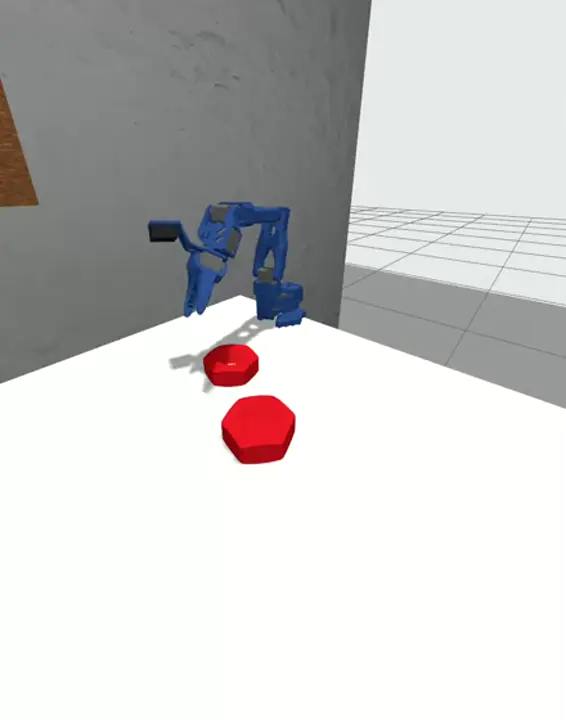
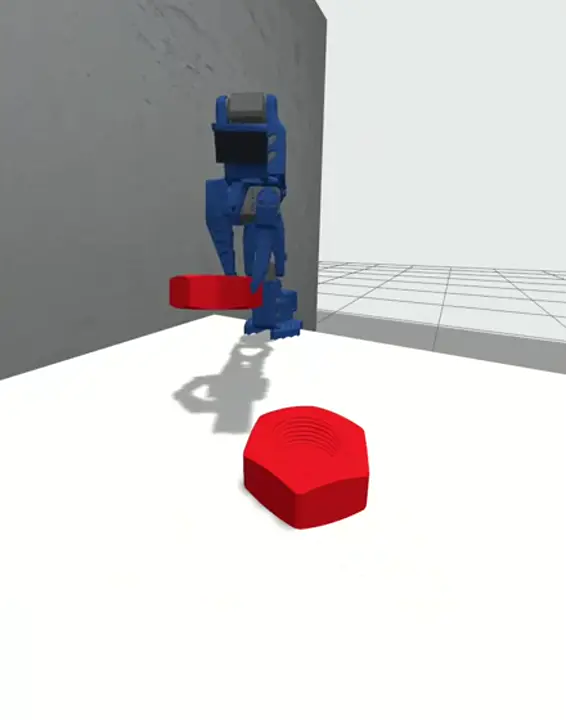
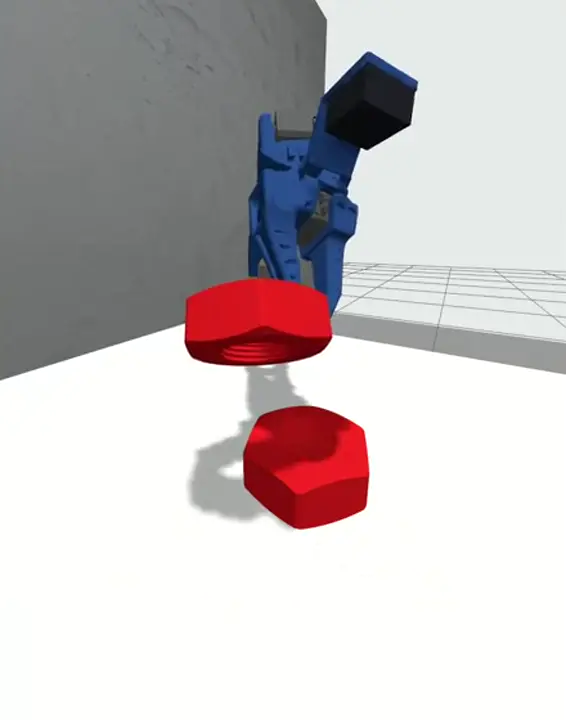
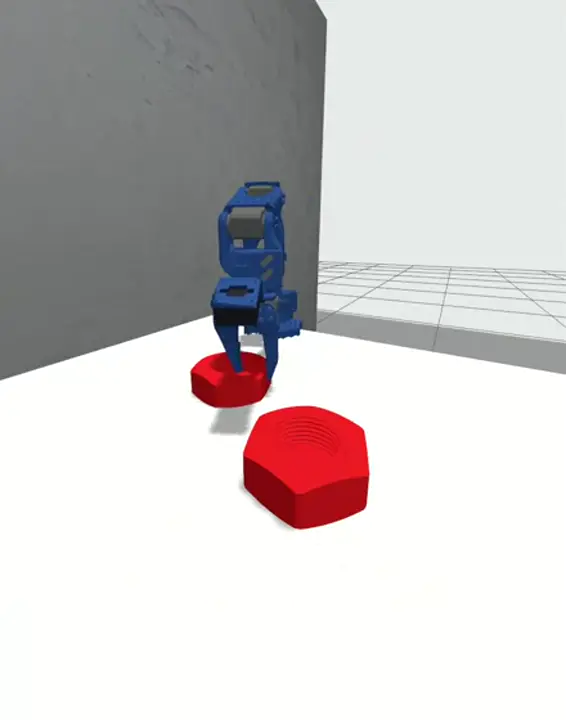
  • Simulated SO-101 stacking a red nut in Gazebo

    ACT policy in Gazebo. Autonomous stacking in simulation

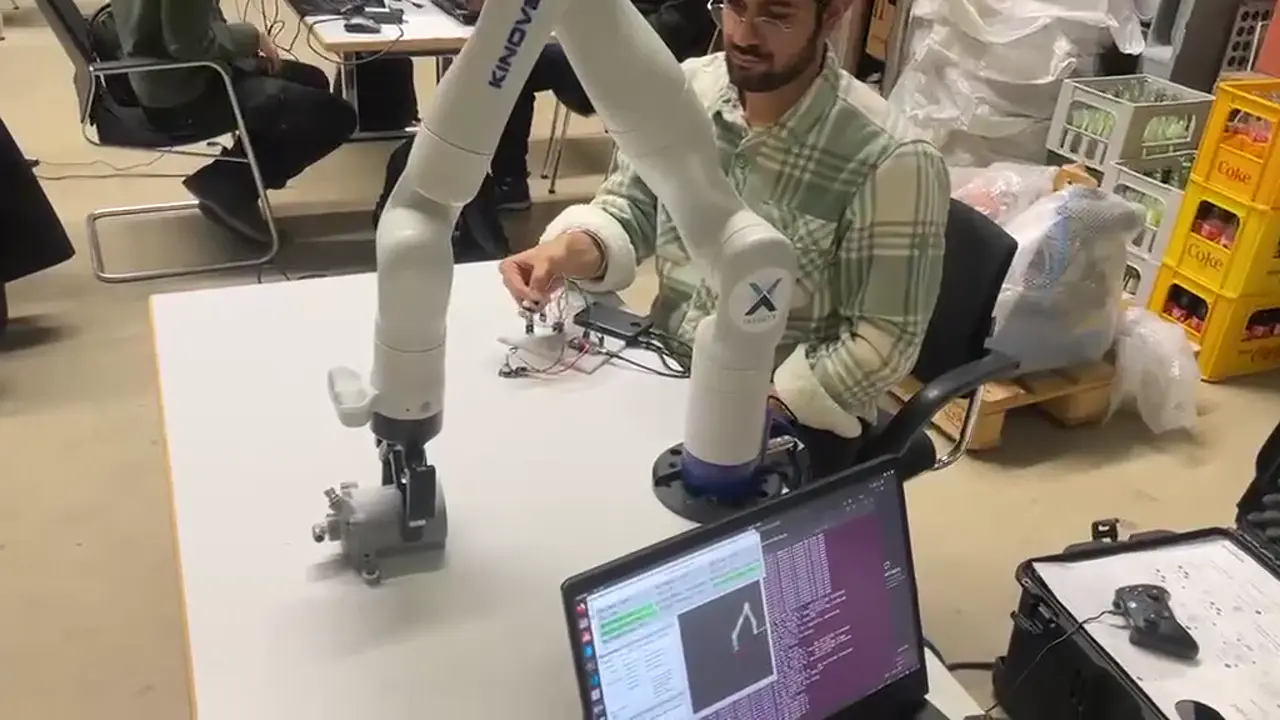
  • Shubham steering a Kinova Gen3 arm with a hand-held sensor

    Kinova Gen3. Hand-held IMU teleoperation

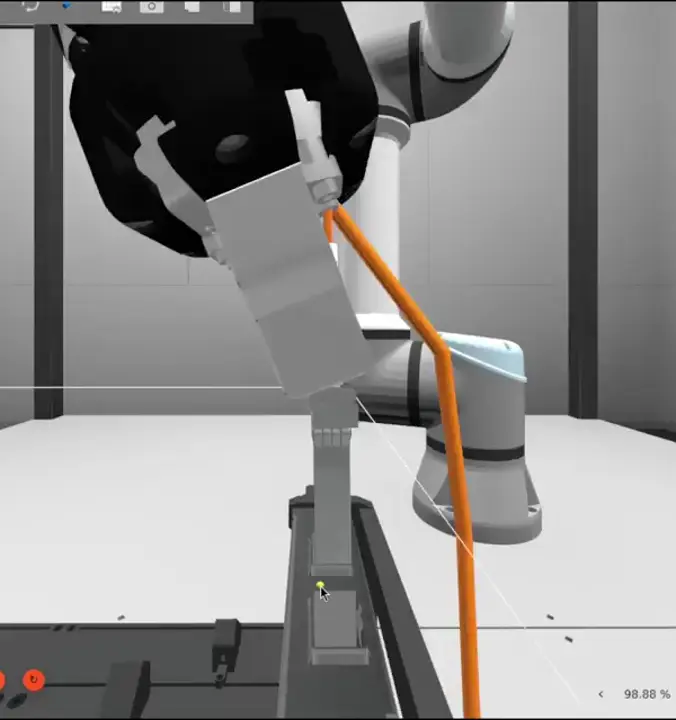
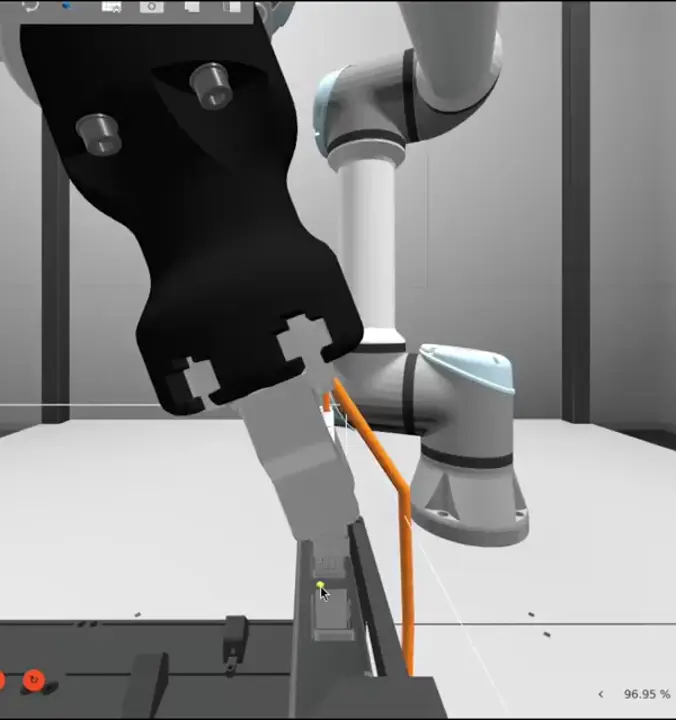
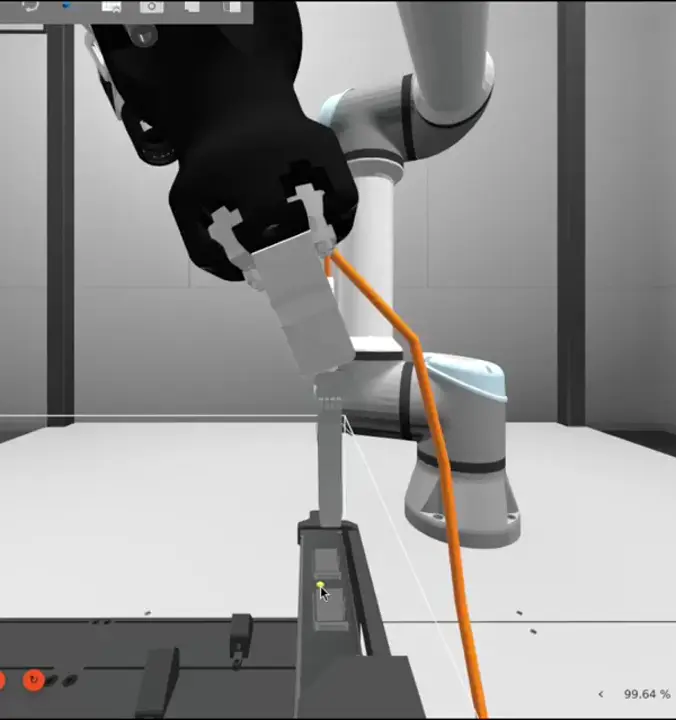
  • Simulated gripper guiding an orange cable plug toward a port

    Intrinsic challenge. Cable insertion, 35th globally

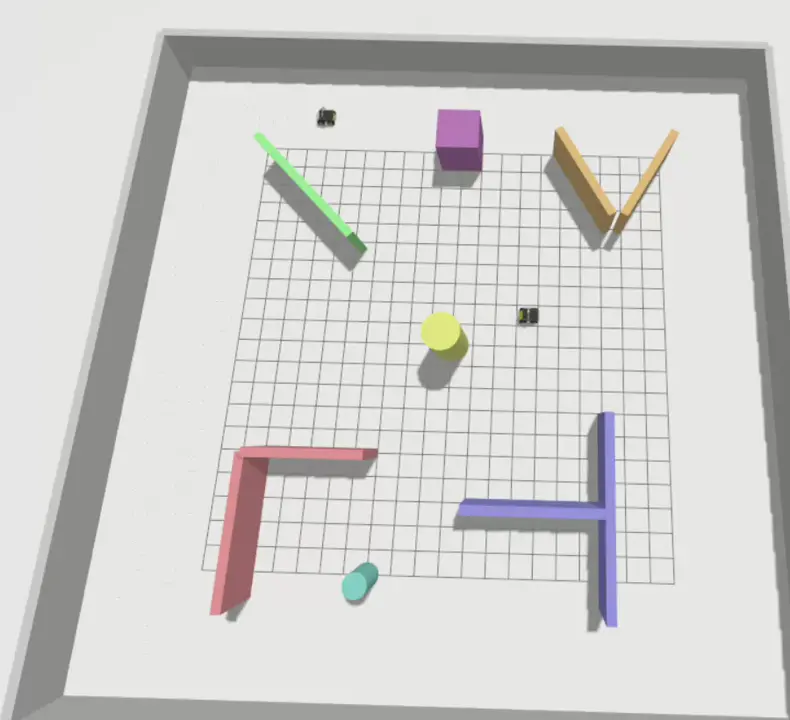
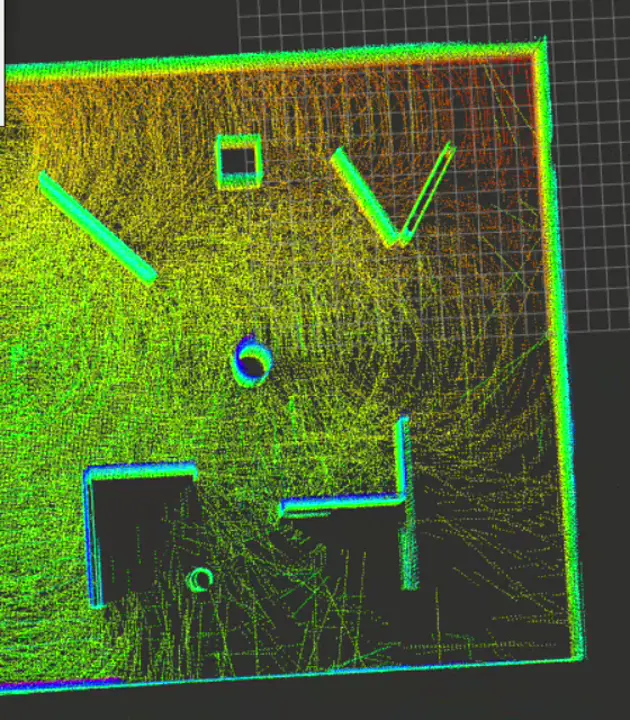
  • Merged lidar map of a walled arena, coloured by height

    Multi-robot graph SLAM. +22.7% map accuracy

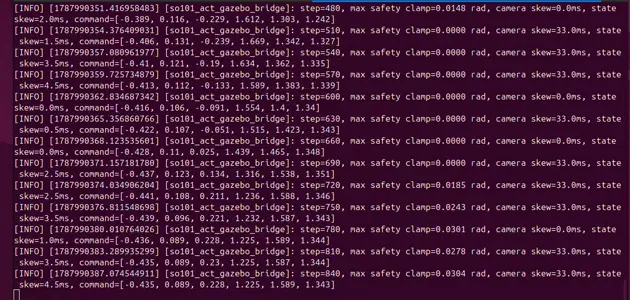
  • Terminal log from the ACT Gazebo bridge listing step, safety clamp and camera skew

    Gazebo bridge log. A safety clamp on every joint command

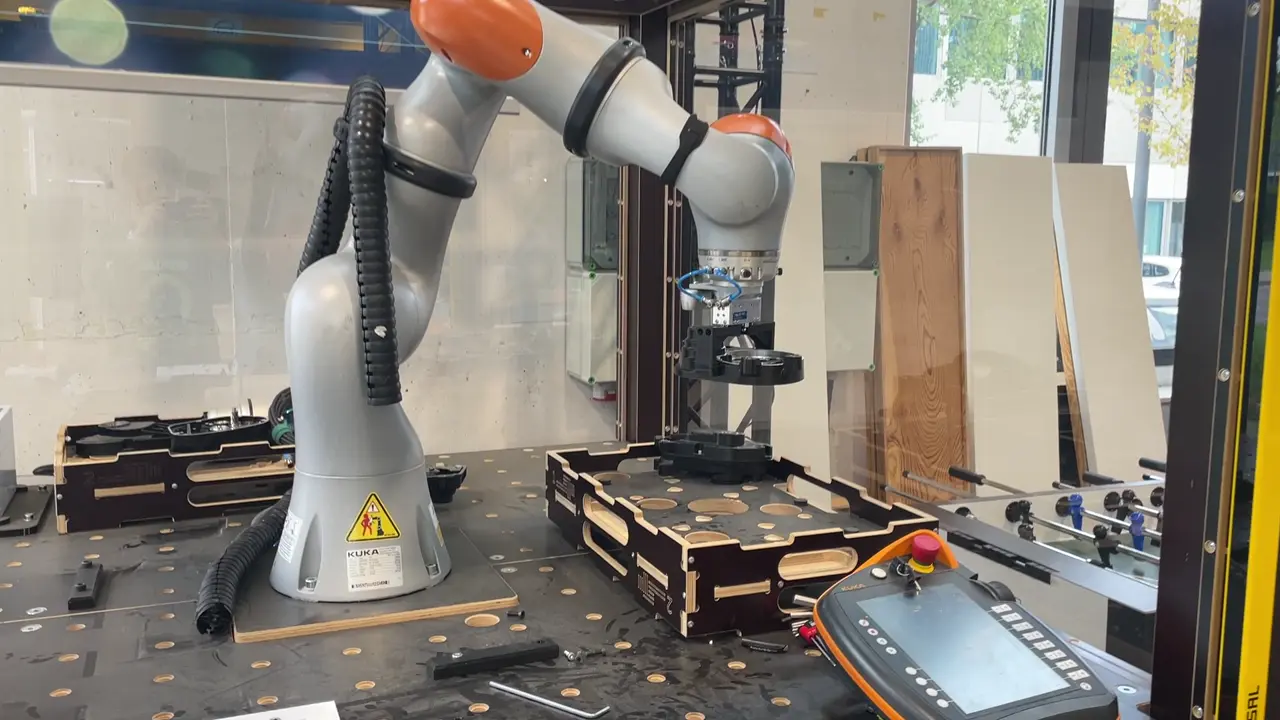
  • KUKA iiwa bent over the fixture during a pick

    KUKA iiwa. Validated pose handed to a MoveIt skill

Shubham Nagar, robot learning

I train robots to learn a specific task, then push them until they succeed at it consistently on real hardware.

Shubham Nagar in front of the Berlin Cathedral
Based in
Aachen, Germany
Available
Full-time, right away
Work authorization
Valid German work visa
Languages
English C1, German A2

About me

I am finishing an MSc in Robotic Systems Engineering at RWTH Aachen, with a GPA of 1.7 and graduation in November 2026. My focus is getting robots to learn a specific manipulation task and succeed at it consistently on real hardware, from the demonstration data to the fine-tuned imitation-learning or vision-language-action policy to scored trials on the physical arm.

My coursework covers Advanced Robotics, Kinematics and Dynamics, Advanced Machine Learning, Reinforcement Learning and Control Systems. Alongside it, I work as a Physical AI research assistant at the WZL Smart Automation Lab, building perception and manipulation for an LLM task planner on a KUKA iiwa.

My master's thesis at MAGMA keeps injection-molded product quality on target under physical process disturbances, using a multi-task Gaussian-process surrogate and contextual inverse optimization. There I also built and shipped a Dash application for training, inspecting and serving surrogate models, with Docker and a GitLab CI pipeline, now used across the company.

Before RWTH, I spent three years as a mechanical design engineer at Dover in Bangalore.

Day to day I use Python, C++, PyTorch, LeRobot, ROS 2, MoveIt 2, Gazebo, Isaac Sim, OpenCV, Docker and Linux.

Experience

  • Physical AI Research Assistant, WZL Smart Automation Lab, RWTH2026 to present
  • ML Developer and Master's Thesis, MAGMA2025 to present
  • Design Engineer, Dover India, Bangalore2021 to 2024

Seven robot projects

  • Wrist camera: gripper closing on a Snickers bar
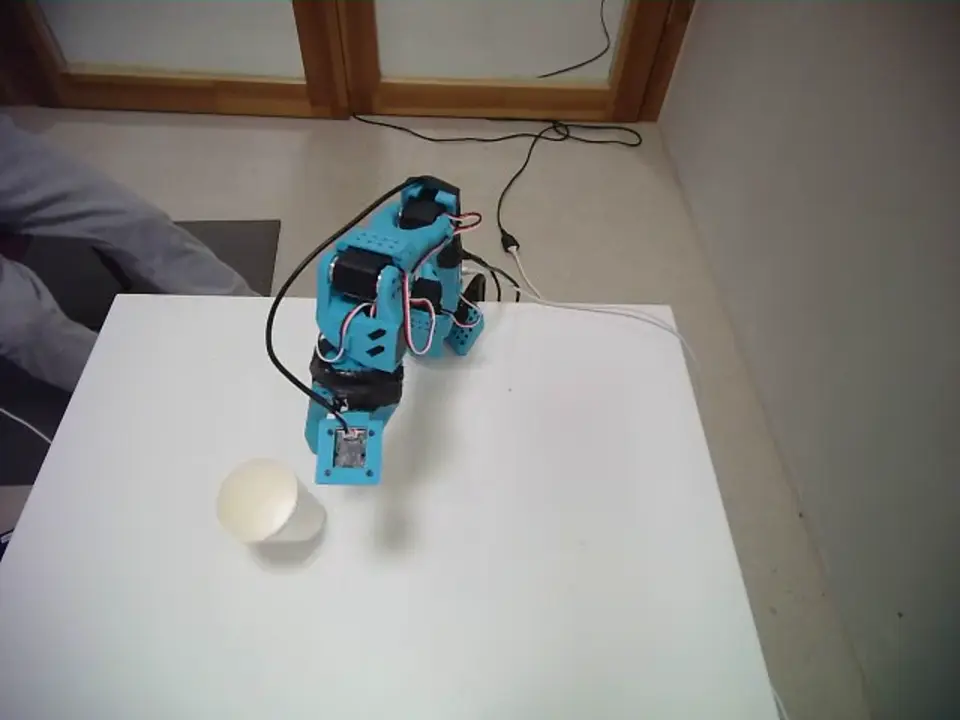
  • SO-101 lifting a paper cup

ERH Physical AI Hackathon, Zurich

FLUX.3 Action on SO-101, clips at 2× speed

2nd in the Imagine, then Act track

October 2026

Team Trainers, 30 hours at DARE campus

We tested Black Forest Labs' FLUX.3 Action world action model zero-shot on a physical SO-101 with a scene camera and a wrist camera, running inference remotely on an NVIDIA H100 through AWS. Calibration issues limited the zero-shot runs. We then collected 100 episodes each of Snickers placement and paper-cup stacking, with other objects scattered on the table, and fine-tuned at batch size 2.

Of the 3,000-, 4,000- and 6,000-step checkpoints, 6,000 steps worked best: 8 of 10 Snickers placements and 5 of 10 cup stacks on the real arm, scored as separate tasks.
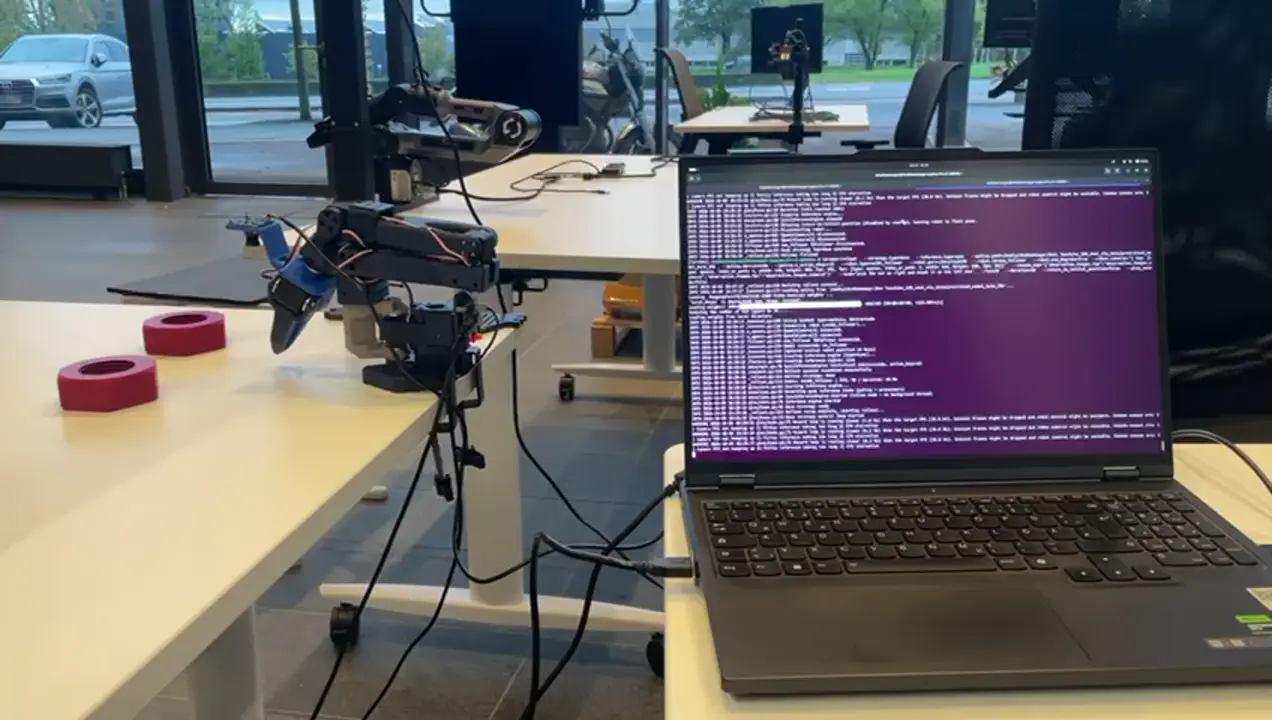
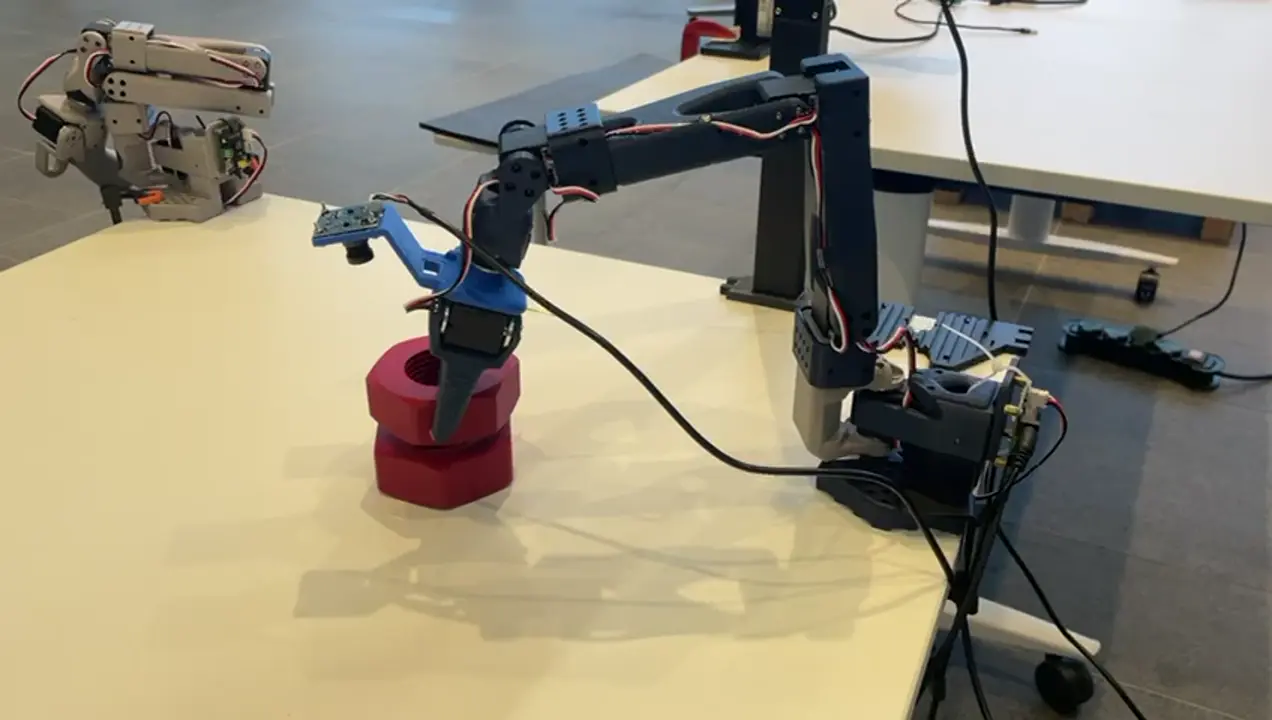
  • The SO-101 setup: two red nuts, the arm and the laptop running the policy
  • SO-101 lowering a nut onto the stack
  • SO-101 releasing a nut on top of the stack
  • SO-101 arm beside two red nuts before a rollout

SmolVLA nut stacking

Physical SO-101, public dataset

75% full-stack success

2026

LeRobot, SmolVLA

I recorded 80 more leader-follower demonstrations and merged them with the original 80 into a public 160-episode, 77,104-frame dataset with a top camera, a first-person camera, and 6-DoF state and action.

I fine-tuned three SmolVLA policies on the first 80 episodes and scored every real-arm rollout by how far it got: grasp, pick, full stack. Batch size 64 at 20,000 steps picked the nut in 90% of rollouts and finished no stacks.

Three checkpoints on the real arm

Share of physical rollouts reaching each stage, by checkpoint
CheckpointGrasp or betterPick or betterFull stack
Batch 16, 20k steps92%88%75%
Batch 64, 10k steps55%52%40%
Batch 64, 20k steps90%90%0%
  • KUKA iiwa above the disassembly fixture
  • KUKA iiwa reaching into the fixture
  • KUKA iiwa close to the fixture with the teach pendant in front

Perception to pick on a KUKA iiwa

WZL Smart Automation Lab, RWTH

Six stages, each tested on hardware

2026 to present

YOLOE, RealSense, MoveIt 2, Jetson AGX Orin

For an LLM task planner in a disassembly cell, I built the path from camera to gripper. Pretrained YOLOE-26s-seg detects and segments the requested object in RealSense images, the calibrated camera-to-robot transform puts it in the iiwa base frame, and validated poses go to deterministic MoveIt skills: approach, grasp, lift, place, release, retreat. The gripper runs over OPC UA.

A hard-coded layer checks kinematic and safety bounds before any action is dispatched. The LLM planner and the ROS 2 execution layer run on an NVIDIA Jetson AGX Orin.

  • Simulated SO-101 reaching toward two red nuts
  • Bridge log listing step, safety clamp and camera skew per command
  • Simulated SO-101 lowering a nut
  • Simulated SO-101 above the finished stack

ACT policy for SO-101 in Gazebo

Matched simulation of the physical task

Autonomous stacking, in simulation

2026

ROS 2, Gazebo, ACT, LeRobot

I rebuilt the physical nut-stacking task in Gazebo and wrote a randomized, headless collector that produced 100 successful multi-camera episodes in LeRobot format. A 52M-parameter Action Chunking with Transformers (ACT) policy, trained from scratch on an RTX 4070 with pretrained ResNet-18 features, runs closed-loop through a bridge that synchronizes camera frames and bounds every joint command.

It stacks autonomously in simulation. It has not been run on the physical arm yet.

  • Simulated arm holding a cable above the insertion fixture
  • Gripper aligning the plug with the port
  • Gripper pressing the plug toward the port

Cable insertion, Intrinsic challenge

Intrinsic AI for Industry Challenge

35th globally, cable inserted in simulation

2026

ROS 2, Gazebo, ACT, diffusion policy, DAgger

The task: a robot arm in Gazebo holds a cable and has to insert its plug into a port, with the start positions randomized every episode. We tuned controllers to generate clean synthetic demonstrations and trained Action Chunking with Transformers (ACT) and diffusion-policy models on them. We then used DAgger to collect more data: the learned policy drives the arm, and a teacher labels the correct action for the states the policy actually reaches. A diffusion policy trained on that data plugged the cable into the port in simulation.

Two failures shaped the approach. The first was compounding error: a policy trained only on clean demonstrations has never seen a slightly wrong state, so once the plug touched the port, a small pose error pushed it somewhere unfamiliar and every further step drifted more. DAgger targets this by adding teacher labels for exactly those states. The second was averaging: the demonstrations reached the port in more than one way, and a model that predicts one average motion blends them into a path that matches none of them. A diffusion policy samples one of the ways instead of averaging them.

  • Gazebo arena with walls and obstacles for two robots
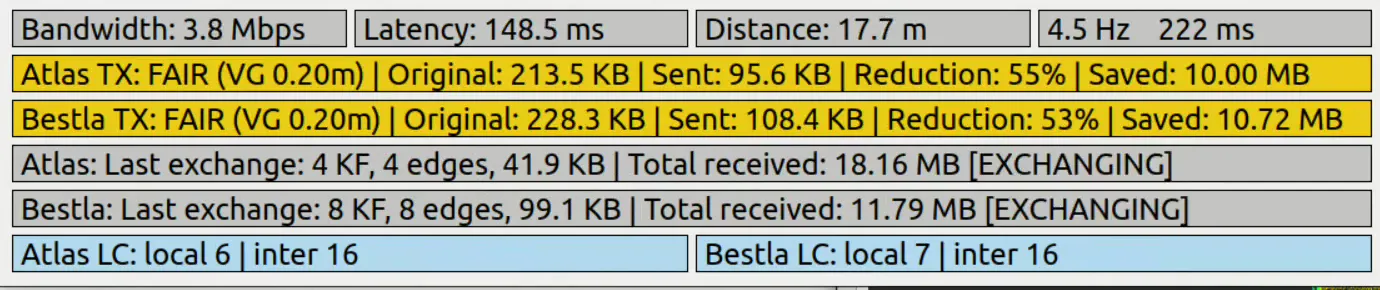
  • Monitoring panel showing bandwidth, latency and data saved per robot
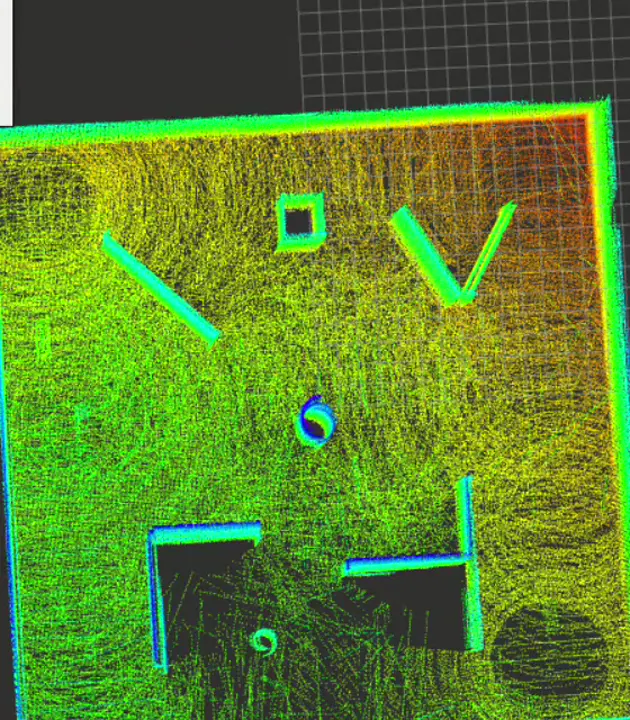
  • Completed merged lidar map

Network-aware multi-robot SLAM

MMI, RWTH Aachen

+22.7% map accuracy on constrained links

November 2025 to May 2026

C++, ROS 2, QEMU, PyQt

I wrote the C++ communication layer for decentralized multi-robot graph SLAM. It reads the current bandwidth and latency of the link between robots and sets the VoxelGrid resolution from them, so the raw lidar point clouds are downsampled more when the network is constrained and sent closer to full resolution when it is not.

I tested it on two robot VMs under QEMU with TAP networking, shaping bandwidth and latency at runtime. It removed the communication bottleneck and improved map accuracy by 22.7% on constrained links. A PyQt monitor shows the link state, the voxel size in use and the data saved for each robot.

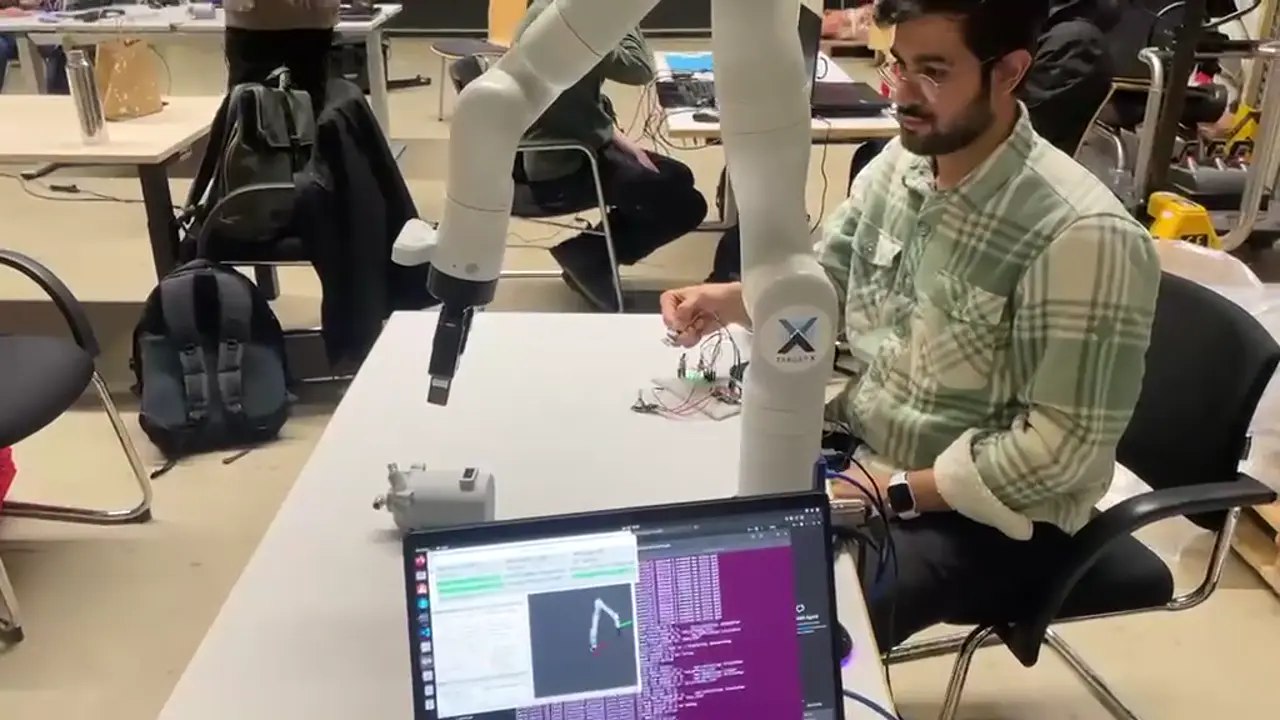
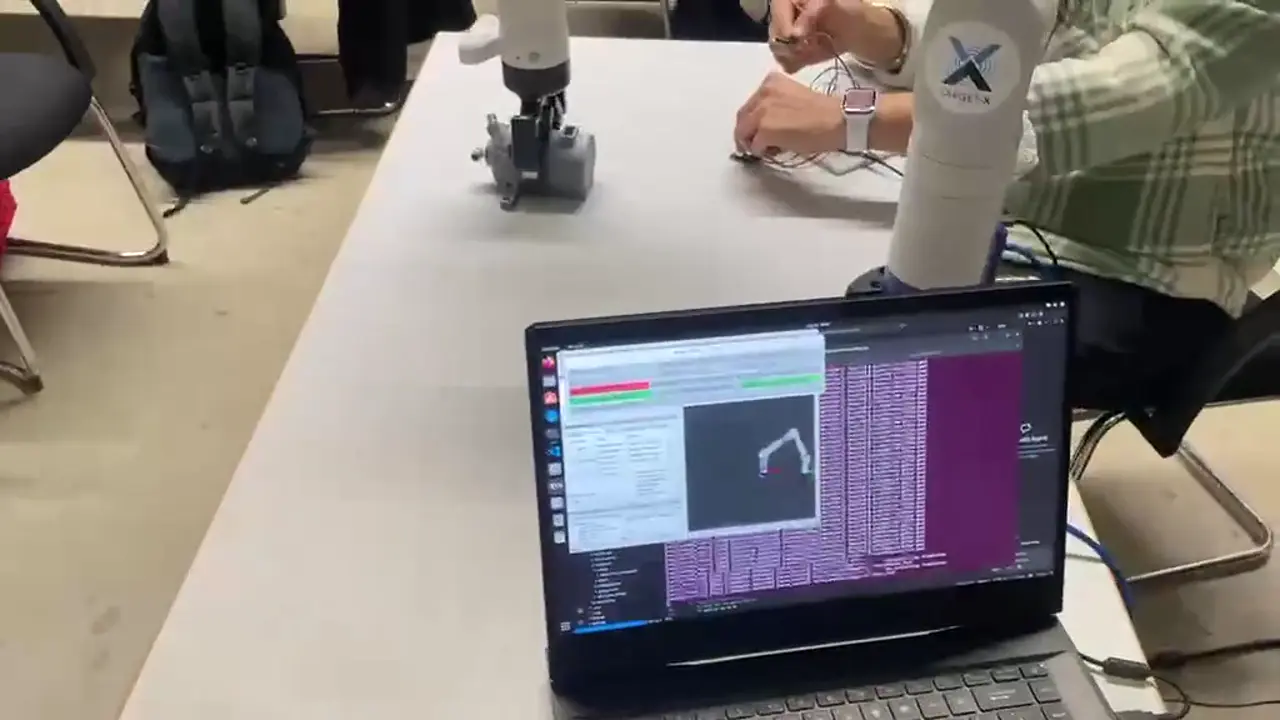
  • Operator seated beside a Kinova Gen3 arm
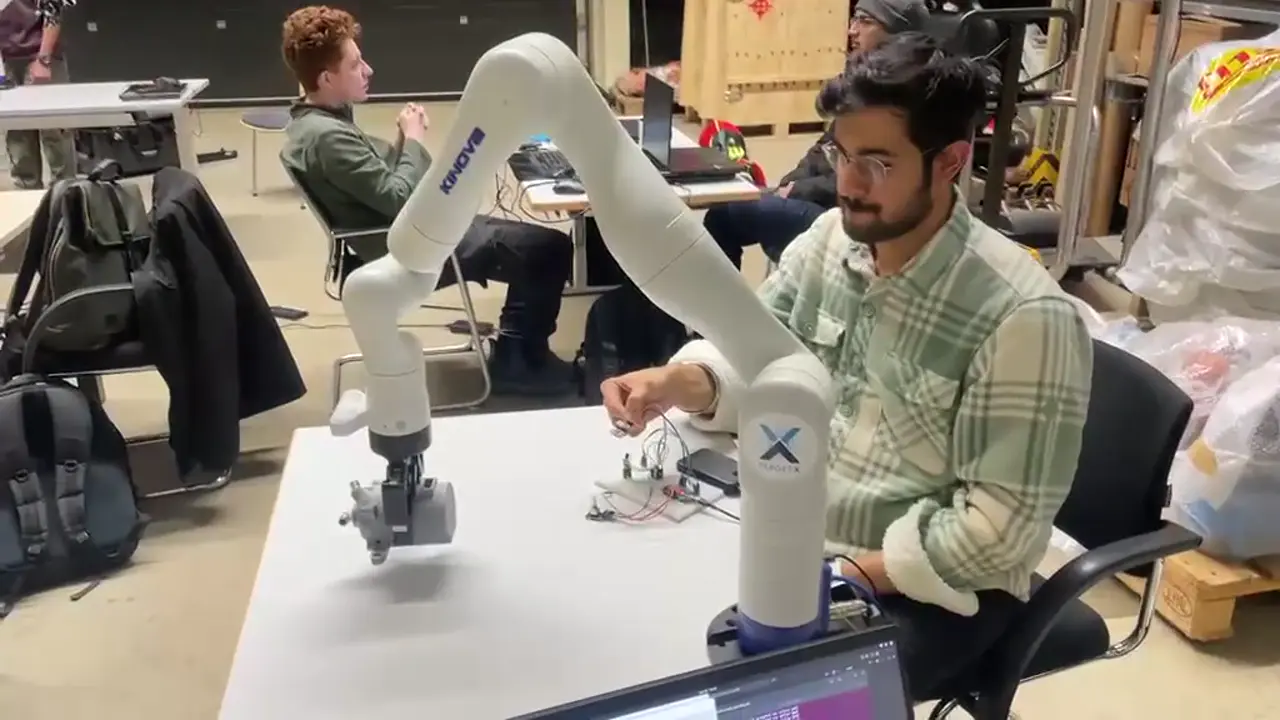
  • Operator rotating the hand-held sensor while the arm follows
  • Kinova gripper over the table with the control laptop in front

IMU teleoperation, Kinova Gen3

WZL, RWTH Aachen

Physical 7-DoF arm

2024 to 2025

ROS 2, MoveIt Servo, Docker

Rotating a hand-held IMU maps, axis by axis, to end-effector velocity through MoveIt Servo on the Kinova ROS 2 drivers. A rotary encoder and IR safety sensors join over Wi-Fi, with control-mode switching, an emergency stop and homing, in one Dockerized stack that runs the same in simulation and on the arm.

Measured results

Results by project
YearProjectMeasureResult
2026ERH Physical AI Hackathon, ZurichImagine, then Act track2nd place
ERH, 6,000-step checkpointSnickers placement, physical SO-1018 of 10
ERH, 6,000-step checkpointPaper-cup stacking, physical SO-1015 of 10
SmolVLA, batch 16, 20k stepsFull stack, physical SO-10175%
SmolVLA, batch 16, 20k stepsPick or better88%
SmolVLA, batch 16, 20k stepsGrasp or better92%
ACT, 52M parametersNut stacking in GazeboAutonomous, simulation only
Intrinsic AI for Industry ChallengeGlobal ranking35th
Intrinsic, diffusion policy with DAgger dataCable insertion in GazeboInserted, simulation only
Network-aware graph SLAMMap accuracy on constrained links+22.7%
2025Master's thesis, MAGMAMulti-task GP surrogate, R²≈ 0.99

Data and models

Hugging Face profile

Datasets

Models

Code

Open to full-time robot-learning roles, available right away.